Landmarks, kinematics, registration
Landmarks and kinematics
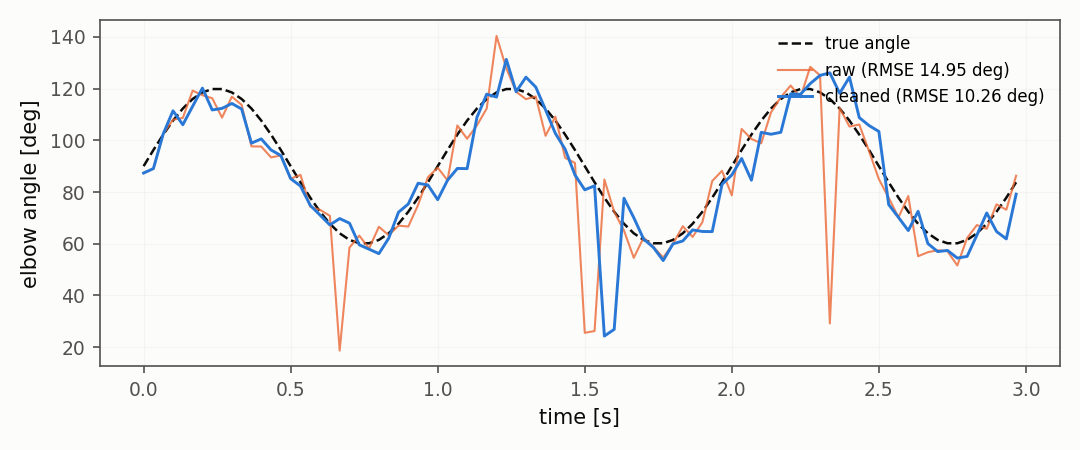
An external pose source (a marker system, a network, the joints of a
robot seen by a camera) delivers points over time. The
LandmarkStream is the
interface, LandmarkCleaner
filters them with a causal Hampel, and
Kinematics turns them into
angles, speeds and a cycle residual that the drift detectors understand.
On 20 synthetic seeds the cleaned series has a smaller error than the
raw one on every seed (Wilcoxon two-sided, A12 = 1.0).
Registration and difference imaging
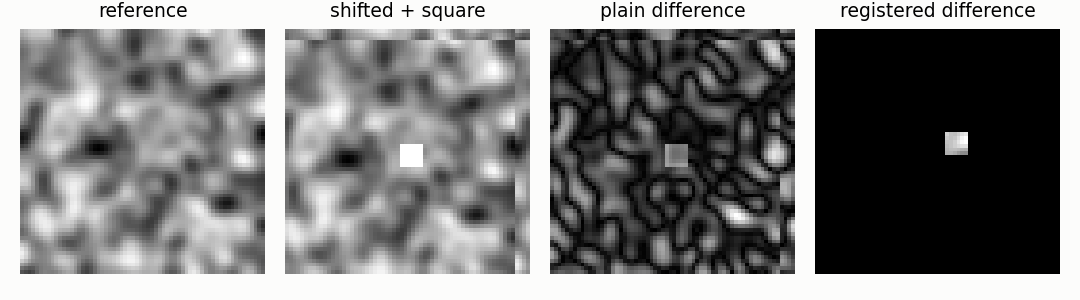
When the camera moves, the difference between two frames is dominated
by the global shift. Registration
estimates the shift with phase correlation, Stabilizer
removes it, and DifferenceImage
shows what really changed. On a pure translation the shift is exact
(0.0 px error on 20 seeds). The kernel convolution of Alard and Lupton
(1998) is not implemented here; the difference is noted in the module
docstring.